Back
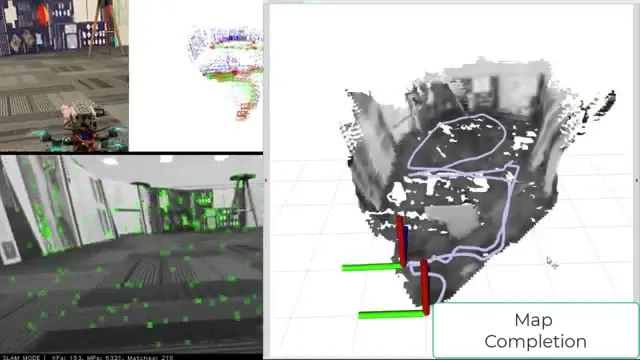
Trajectory stress tests and a visual localization shootout end with ORB-SLAM flying a real office and handing back a dense map
slam
computer vision